Wheel Loader Controls and Input Bindings
Driving, steering, lift arm, and bucket control inputs for the Wheel loader model WL 10.
Drivetrain and Articulated Steering Inputs
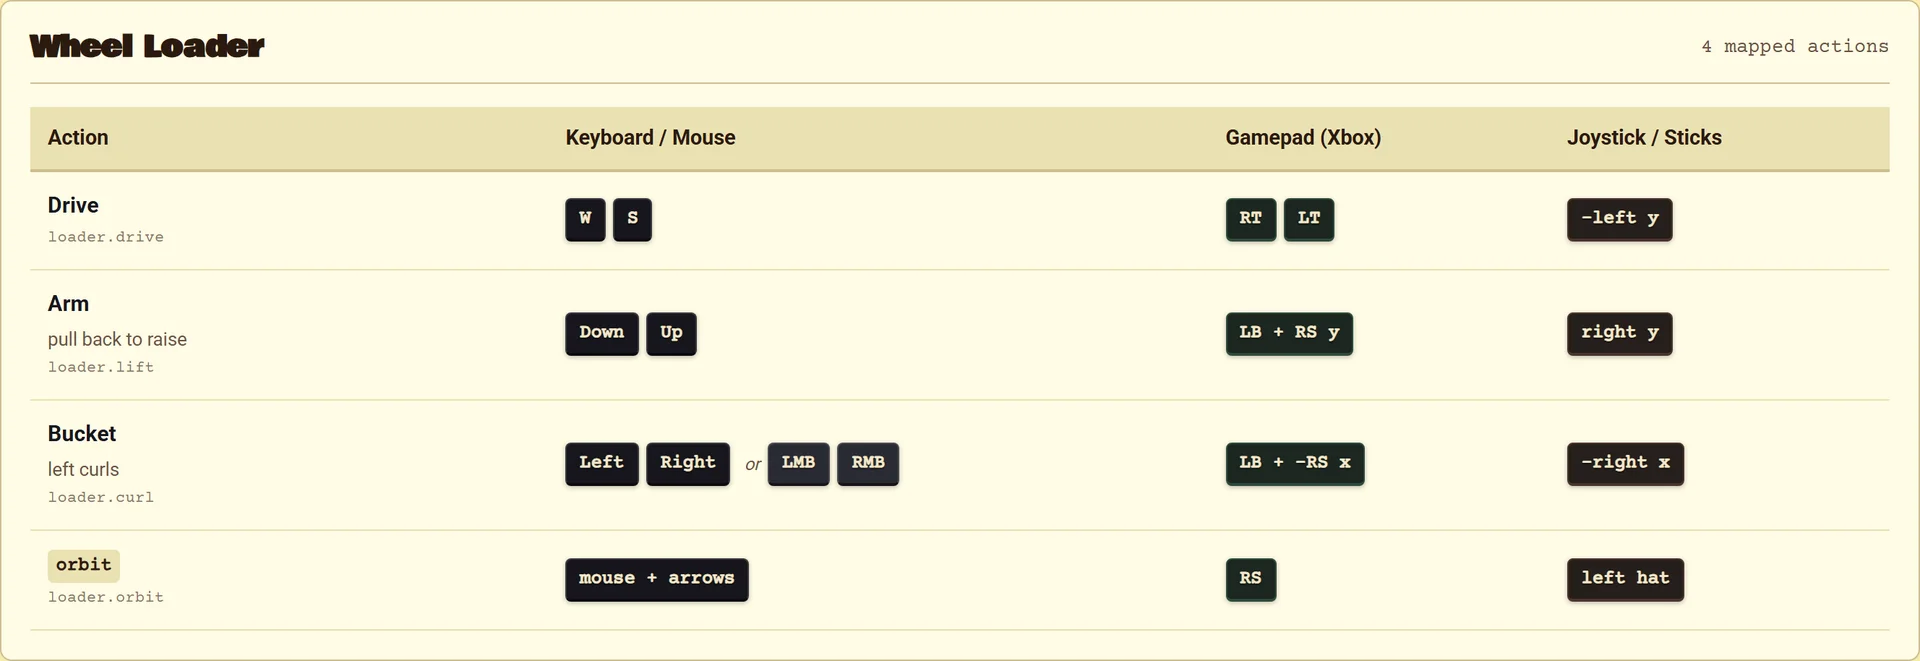
The 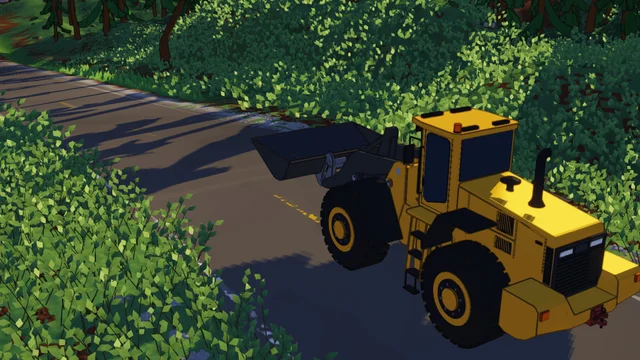 Wheel loader model WL 10 is cataloged in the Loaders section with absent demo status. Driving forward and reverse uses W / S on keyboard, RT / LT on gamepad, and -left y on joystick. Steering uses A / D on keyboard, -LS x on gamepad, and -left x on joystick. The steering geometry provides a maximum turn angle of 40 degrees.
Boom Arm Elevation and Bucket Hydraulics
Raising and lowering the loader arm uses Down / Up on keyboard, LB + RS y on gamepad, and right y on joystick. Curling and dumping the  Bucket uses Left / Right on keyboard, LB + -RS x on gamepad, and -right x on joystick. The lift arm structure has a mass of 950 kg and operates between -42 degrees and 48.5 degrees.
Implement Specifications and Capacity
The standard loader configuration mounts a 1.8 m3 Bucket implement. The Bucket measures 1.25 m in depth with a wall height of 0.8 m.